Odyssey-3 shares a world-model backbone across robots, cars, drones, and games
Odyssey has announced Odyssey-3, an autoregressive diffusion transformer designed to simulate environments and control several kinds of embodied systems. The company presents it as a reusable foundation model: developers keep the pretrained backbone fixed and train a compact action decoder on observations and controls from a target robot, vehicle, drone, or game. If the reported transfer holds across independent tests, the design could reduce platform-specific data collection and full-model retraining.
One backbone, many controllers
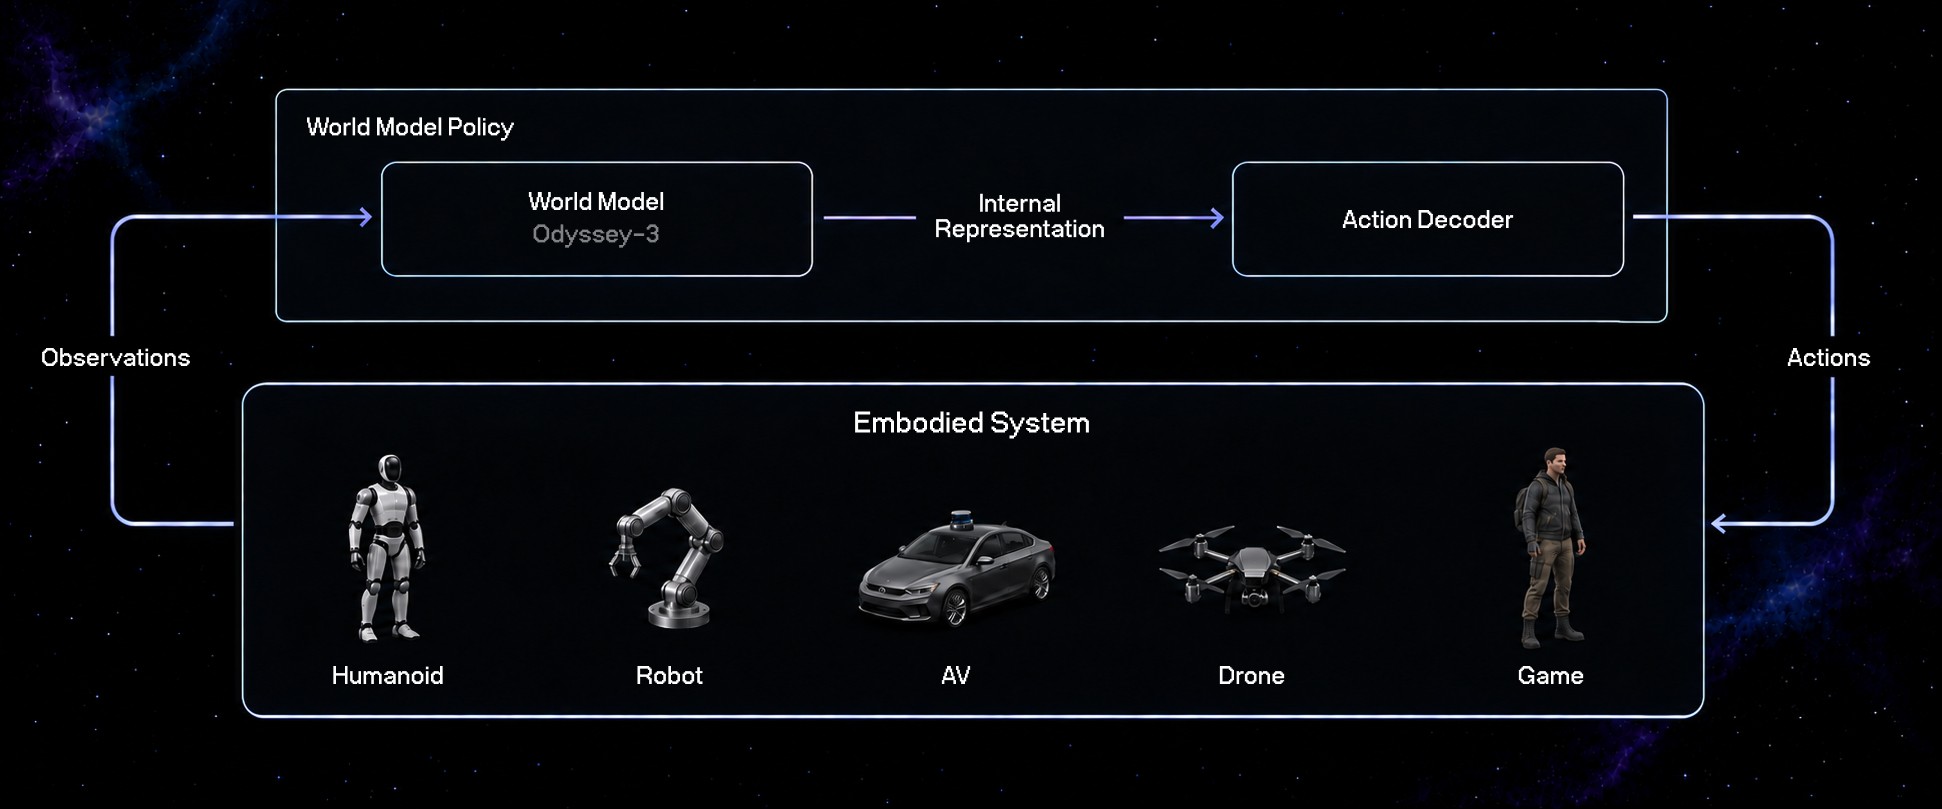
Odyssey describes its model as an autoregressive diffusion transformer. Autoregression predicts sequences one step at a time, and diffusion generates outputs through iterative refinement. Odyssey combines those methods to model how environments evolve and how actions change them. According to the company, the same pretrained backbone supports every demonstration.
For each target system, developers collect experiential data consisting of paired observations and actions. A learned decoder then translates the model’s internal representations into joint movements, steering inputs, flight controls, or game commands. Training updates the decoder while the backbone remains frozen, preserving its pretrained parameters and limiting the number of components that require adaptation.
Five demos, different limits
Odyssey reports control experiments across five domains, plus a separate project that uses the model to train other AI agents.
PROWL turns the model into a training environment
Odyssey also uses Odyssey-3 as an interactive simulator through a companion project called PROWL. AI agents act inside generated environments and learn from the consequences. Their failures can supply examples for improving the world model, while the model produces additional situations for training the agents.
That feedback loop could support stress testing and exposure to rare scenarios before hardware deployment. Simulation alone cannot establish physical safety because modeling errors may omit real hazards or create unrealistic ones. Agents trained through PROWL would still require evaluation on physical systems and under independently designed tests.
The economics hinge on transfer
Embodied AI systems commonly depend on data collected for a particular body, task, and environment. A transferable backbone concentrates broad dynamics learning in pretraining and limits later work to a smaller decoder. Potential gains include fewer trainable parameters, shorter adaptation cycles, and reuse across control interfaces, provided the backbone captures the physics and causal structure each platform requires.
The cross-game experiment offers evidence for representations that extend beyond one environment. A policy learned from GTA V footage generated movement for a different character in Red Dead Redemption 2. One example cannot establish broad transfer, however, or distinguish abstract locomotion knowledge from transfer enabled by similar controls and visual patterns.
The evidence still has gaps
- Independent validation: The figures come from Odyssey’s announcement. Independent benchmark results are not yet available.
- Driving metrics: The 77% result is relative to a policy trained on real footage. Developers still need absolute intervention-free distances, route details, traffic conditions, trial counts, and variance.
- Physical coverage: The drone experiment remains in simulation. The robot-arm and humanoid claims need task-level success rates across hardware, environments, and viewpoints.
- Collection costs: Tens of hours is modest by embodied-AI standards, but teleoperation remains expensive and must be repeated for each new embodiment.
- Implementation details: The announcement does not specify the parameter count, pretraining-data composition, inference hardware, control frequency, latency, or decoder-training recipe.
- Generalization: Odyssey has announced a benchmarking partnership with Poke & Wiggle to test the model across bodies and viewpoints. Results from that work have not been published.
Access remains gated
Odyssey says it plans to release Odyssey-3 publicly within weeks of the announcement and directs developers to its developer portal. At publication, no public download or pricing had been announced. The company also has not specified the release format, license, checkpoint access, API limits, or hardware requirements.
Odyssey says organizations in robotics, autonomous driving, gaming, and defense are already using the model, though it has not identified those users or described their deployments. Independent benchmarks will need to measure data efficiency, control reliability, latency, and sim-to-real transfer against body-specific baselines. Consistent gains on those measures would support Odyssey’s case for a shared foundation model across embodied systems.